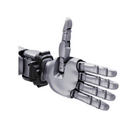
- 21 joints, every one driven Each of the 21 joints has its own direct-drive, backdrivable motor: five in the thumb and four in each finger, side-to-side abduction included.
- 451-taxel tactile palm A full-palm piezoresistive array of 451 taxels reads contact from 0 to 20 N at 0.01 N resolution.
- 100 N grip, 25 N pinch BrainCo rates the active grip at 100 N or more and the fingertip pinch at 25 N or more, with a 20 kg hand payload and 5 kg on the four fingers.
- 33 grasp types BrainCo reports a full Kapandji score and all 33 grasps of the Feix taxonomy, on objects from 10 to 150 mm across.
- 0.33 s joint motion Joints open or close in 0.33 s and repeat to 0.1°.
- EtherCAT, CAN FD and RS-485 All three buses run at a 500 Hz communication rate, on a 16–85 V supply.
- Four control modes Position, MIT force-position, admittance and zero-torque control, with Python and C/C++ SDKs, ROS and simulation support for Isaac Lab and MuJoCo.

Description
The BrainCo Revo 3 U21T is the tactile version of BrainCo's Revo 3, a 21-degree-of-freedom dexterous robotic hand, supplied here for the Unitree H2 humanoid as one hand, left or right, with an RGB camera. Every one of its 21 joints is driven by its own direct-drive, backdrivable motor: five in the thumb and four in each finger, side-to-side abduction included, with no coupled or passive joints.
The U21T adds a full-palm piezoresistive tactile array of 451 taxels that measures contact from 0 to 20 N at 0.01 N resolution. For an H2 lab working on in-hand manipulation, slip handling or learning from contact, that is a pressure map of the whole grasp to pair with joint data and camera images. BrainCo reports a full score on the Kapandji thumb-opposition test and all 33 grasp types of the Feix taxonomy.
BrainCo rates the active grip at 100 N or more, the fingertip pinch at 25 N or more and the payload at 20 kg for the hand and 5 kg on the four fingers. Joints open or close in 0.33 s, repeat to 0.1° and close on objects from 10 mm to 150 mm across, and the hand measures 216 × 108 × 50 mm. It talks EtherCAT, CAN FD or RS-485 at 500 Hz on a 16–85 V supply, runs position, MIT force-position, admittance and zero-torque control, and comes with Python and C/C++ SDKs, ROS support and simulation support for Isaac Lab and MuJoCo.
The Revo 3 U21VT for the H2 trades part of the palm array for vision-based tactile fingertips, and the Revo 2 Tactile for the H2 is the lighter 11-DoF option with fingertip sensing. For robots other than the H2, see BrainCo's Revo 3-21 Touch, or compare all our dexterous robotic hands.
Key Capabilities
- 21 joints, every one driven: Each of the 21 joints has its own direct-drive, backdrivable motor: five in the thumb and four in each finger, side-to-side abduction included.
- 451-taxel tactile palm: A full-palm piezoresistive array of 451 taxels reads contact from 0 to 20 N at 0.01 N resolution.
- 100 N grip, 25 N pinch: BrainCo rates the active grip at 100 N or more and the fingertip pinch at 25 N or more, with a 20 kg hand payload and 5 kg on the four fingers.
- 33 grasp types: BrainCo reports a full Kapandji score and all 33 grasps of the Feix taxonomy, on objects from 10 to 150 mm across.
- 0.33 s joint motion: Joints open or close in 0.33 s and repeat to 0.1°.
- EtherCAT, CAN FD and RS-485: All three buses run at a 500 Hz communication rate, on a 16–85 V supply.
- Four control modes: Position, MIT force-position, admittance and zero-torque control, with Python and C/C++ SDKs, ROS and simulation support for Isaac Lab and MuJoCo.
Buying through Robotix Market
This unit is sourced new through established distribution channels and ships worldwide with the manufacturer warranty. Technical support is coordinated with the manufacturer's own service network. Deployment scope, configuration, and commissioning responsibilities are agreed as part of the quotation — on-site installation is not included in the product price.
Features
Specs
| Brand | BrainCo |
|---|---|
| Model | Revo 3 U21T |
| Compatible robot | Unitree H2 |
| Hand side | Left or right, one hand per unit, chosen with the order |
| Fingers | 5 |
| Degrees of freedom | 21, all active, one motor per joint |
| Joint layout | Thumb 5 (CMC abduction, CMC rotation, CMC flexion, MCP, IP); index, middle, ring and little finger 4 each (abduction, MCP, PIP, DIP) |
| Drive | Direct-drive, backdrivable joints |
| Thumb joint ranges | CMC abduction 0–110°, CMC rotation 0–105°, CMC flexion 0–75°, MCP −10° to 90°, IP −20° to 90° |
| Finger joint ranges | MCP −5° to 90°, PIP −10° to 90°, DIP −20° to 90°; abduction index −10° to 30°, middle −20° to 25°, ring −25° to 20°, little −30° to 10° |
| Hand dimensions | 216 × 108 × 50 mm |
| Maximum active grip force | ≥ 100 N |
| Maximum fingertip pinch force | ≥ 25 N |
| Total hand payload | 20 kg |
| Four-finger payload | 5 kg |
| Repeatability | 0.1° |
| Joint open/close time | 0.33 s |
| Grasp diameter | 10–150 mm |
| Dexterity | Full score on the Kapandji test; 33 grasp types of the Feix taxonomy |
| Tactile sensing | Full-palm piezoresistive array |
| Tactile taxels | 451 |
| Tactile force range | 0–20 N |
| Tactile resolution | 0.01 N |
| Fingertip vision-tactile sensing | None (fitted on the Revo 3 U21VT) |
| Mainboard sensors | IMU and temperature sensor |
| Communication interfaces | EtherCAT, CAN FD, RS-485 |
| Communication frequency | 500 Hz |
| Supply voltage | 16–85 V |
| Maximum current | 10 A at 24 V |
| Control modes | Position, MIT force-position, admittance and zero-torque |
| Software | Python and C/C++ SDKs, ROS; simulation support for Isaac Lab, MuJoCo, ManiSkill and NVIDIA Omniverse |
| Camera | RGB camera included; model and mounting confirmed with the quotation |
| Weight | Confirm at quote |
| Mounting and cabling on your H2 | Confirm at quote |
Industries
Frequently Asked Questions
The BrainCo Revo 3 U21T Tactile Dexterous Hand for Unitree H2 is priced at 116 990 zł in your market.
21, all active: five in the thumb and four in each of the index, middle, ring and little fingers, each joint with its own direct-drive, backdrivable motor. Nothing is coupled or passive, so every joint can be commanded on its own.
A full-palm piezoresistive array of 451 taxels that measures 0–20 N at 0.01 N resolution, giving a pressure map of the whole grasp to pair with the joint data.
BrainCo rates the active grip at 100 N or more and the fingertip pinch at 25 N or more. The hand carries 20 kg in total and 5 kg on the four fingers, and grasps objects from 10 mm to 150 mm across.
The U21VT adds vision-based tactile sensing in the fingertips, with 2,000 markers that detect deformation down to 130 µm, and pairs it with a 336-taxel palm array. The U21T has the larger 451-taxel palm array and no fingertip vision sensing; the 21-DoF mechanism is the same.
Over EtherCAT, CAN FD or RS-485 at 500 Hz, on a 16–85 V supply. Each unit is one hand, left or right, supplied with an RGB camera; mounting and cabling for your H2 are confirmed with the quotation.
BrainCo Revo 3 U21T Tactile Dexterous Hand for Unitree H2
- Regular price
- 116 990,00 zł
- Sale price
Recently Viewed
You haven't viewed any products yet.